MMW
RADAR
RADAR
FPGA
FUSION CORE
FUSION CORE
HOST
AUTOPILOT
AUTOPILOT
THERMAL
IMAGER
IMAGER
VALIDATED
POSITION FIX
POSITION FIX
NAV DRONE
PLANNING
PLANNING
INERTIAL
IMU
IMU
REFERENCE
IMAGERY IN
IMAGERY IN
VIDEO +
TELEMETRY OUT
TELEMETRY OUT
FLIGHT CONTROL STAYS WITH THE HOST AUTOPILOT — SHOAL-OS SUPPLIES THE FIX
TrackFusion · signal pathschematic
CAPABILITIES
- Radar in the matching loop — all-weather, day and night
- Validated position fix issued to the autopilot
- Inertial bridging between imagery matches
- FPGA processing — fixed latency at 200–300 km/h
- Nav Drone mission-planning tool
- Host autopilot keeps flight control throughout
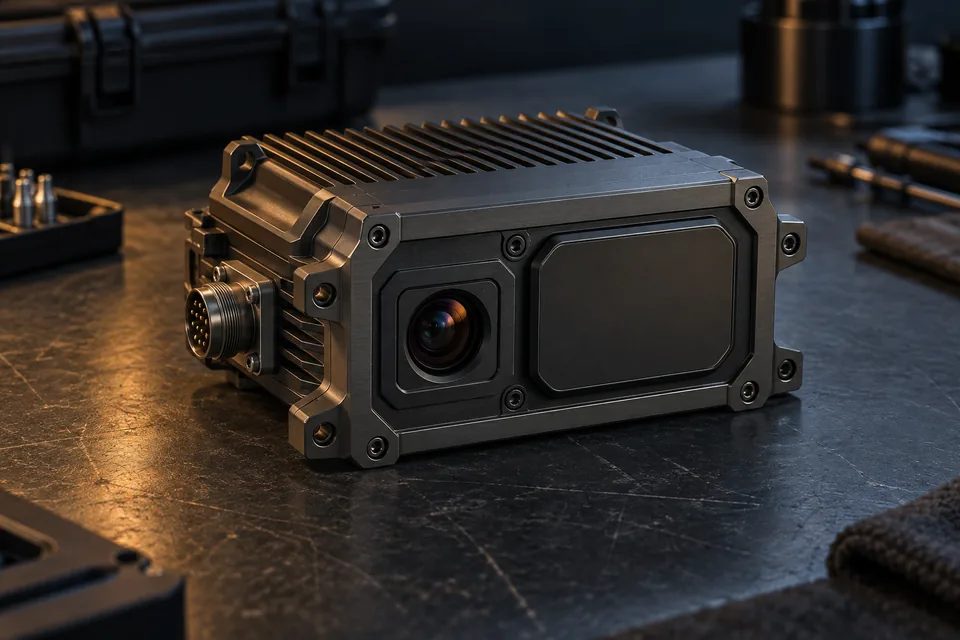
TrackFusion matches live sensor data against imagery prepared by RECONN.EARTH. Inertial sensing bridges the intervals between matches. The host autopilot receives the validated position and retains flight control.